Drone Calculator Overview
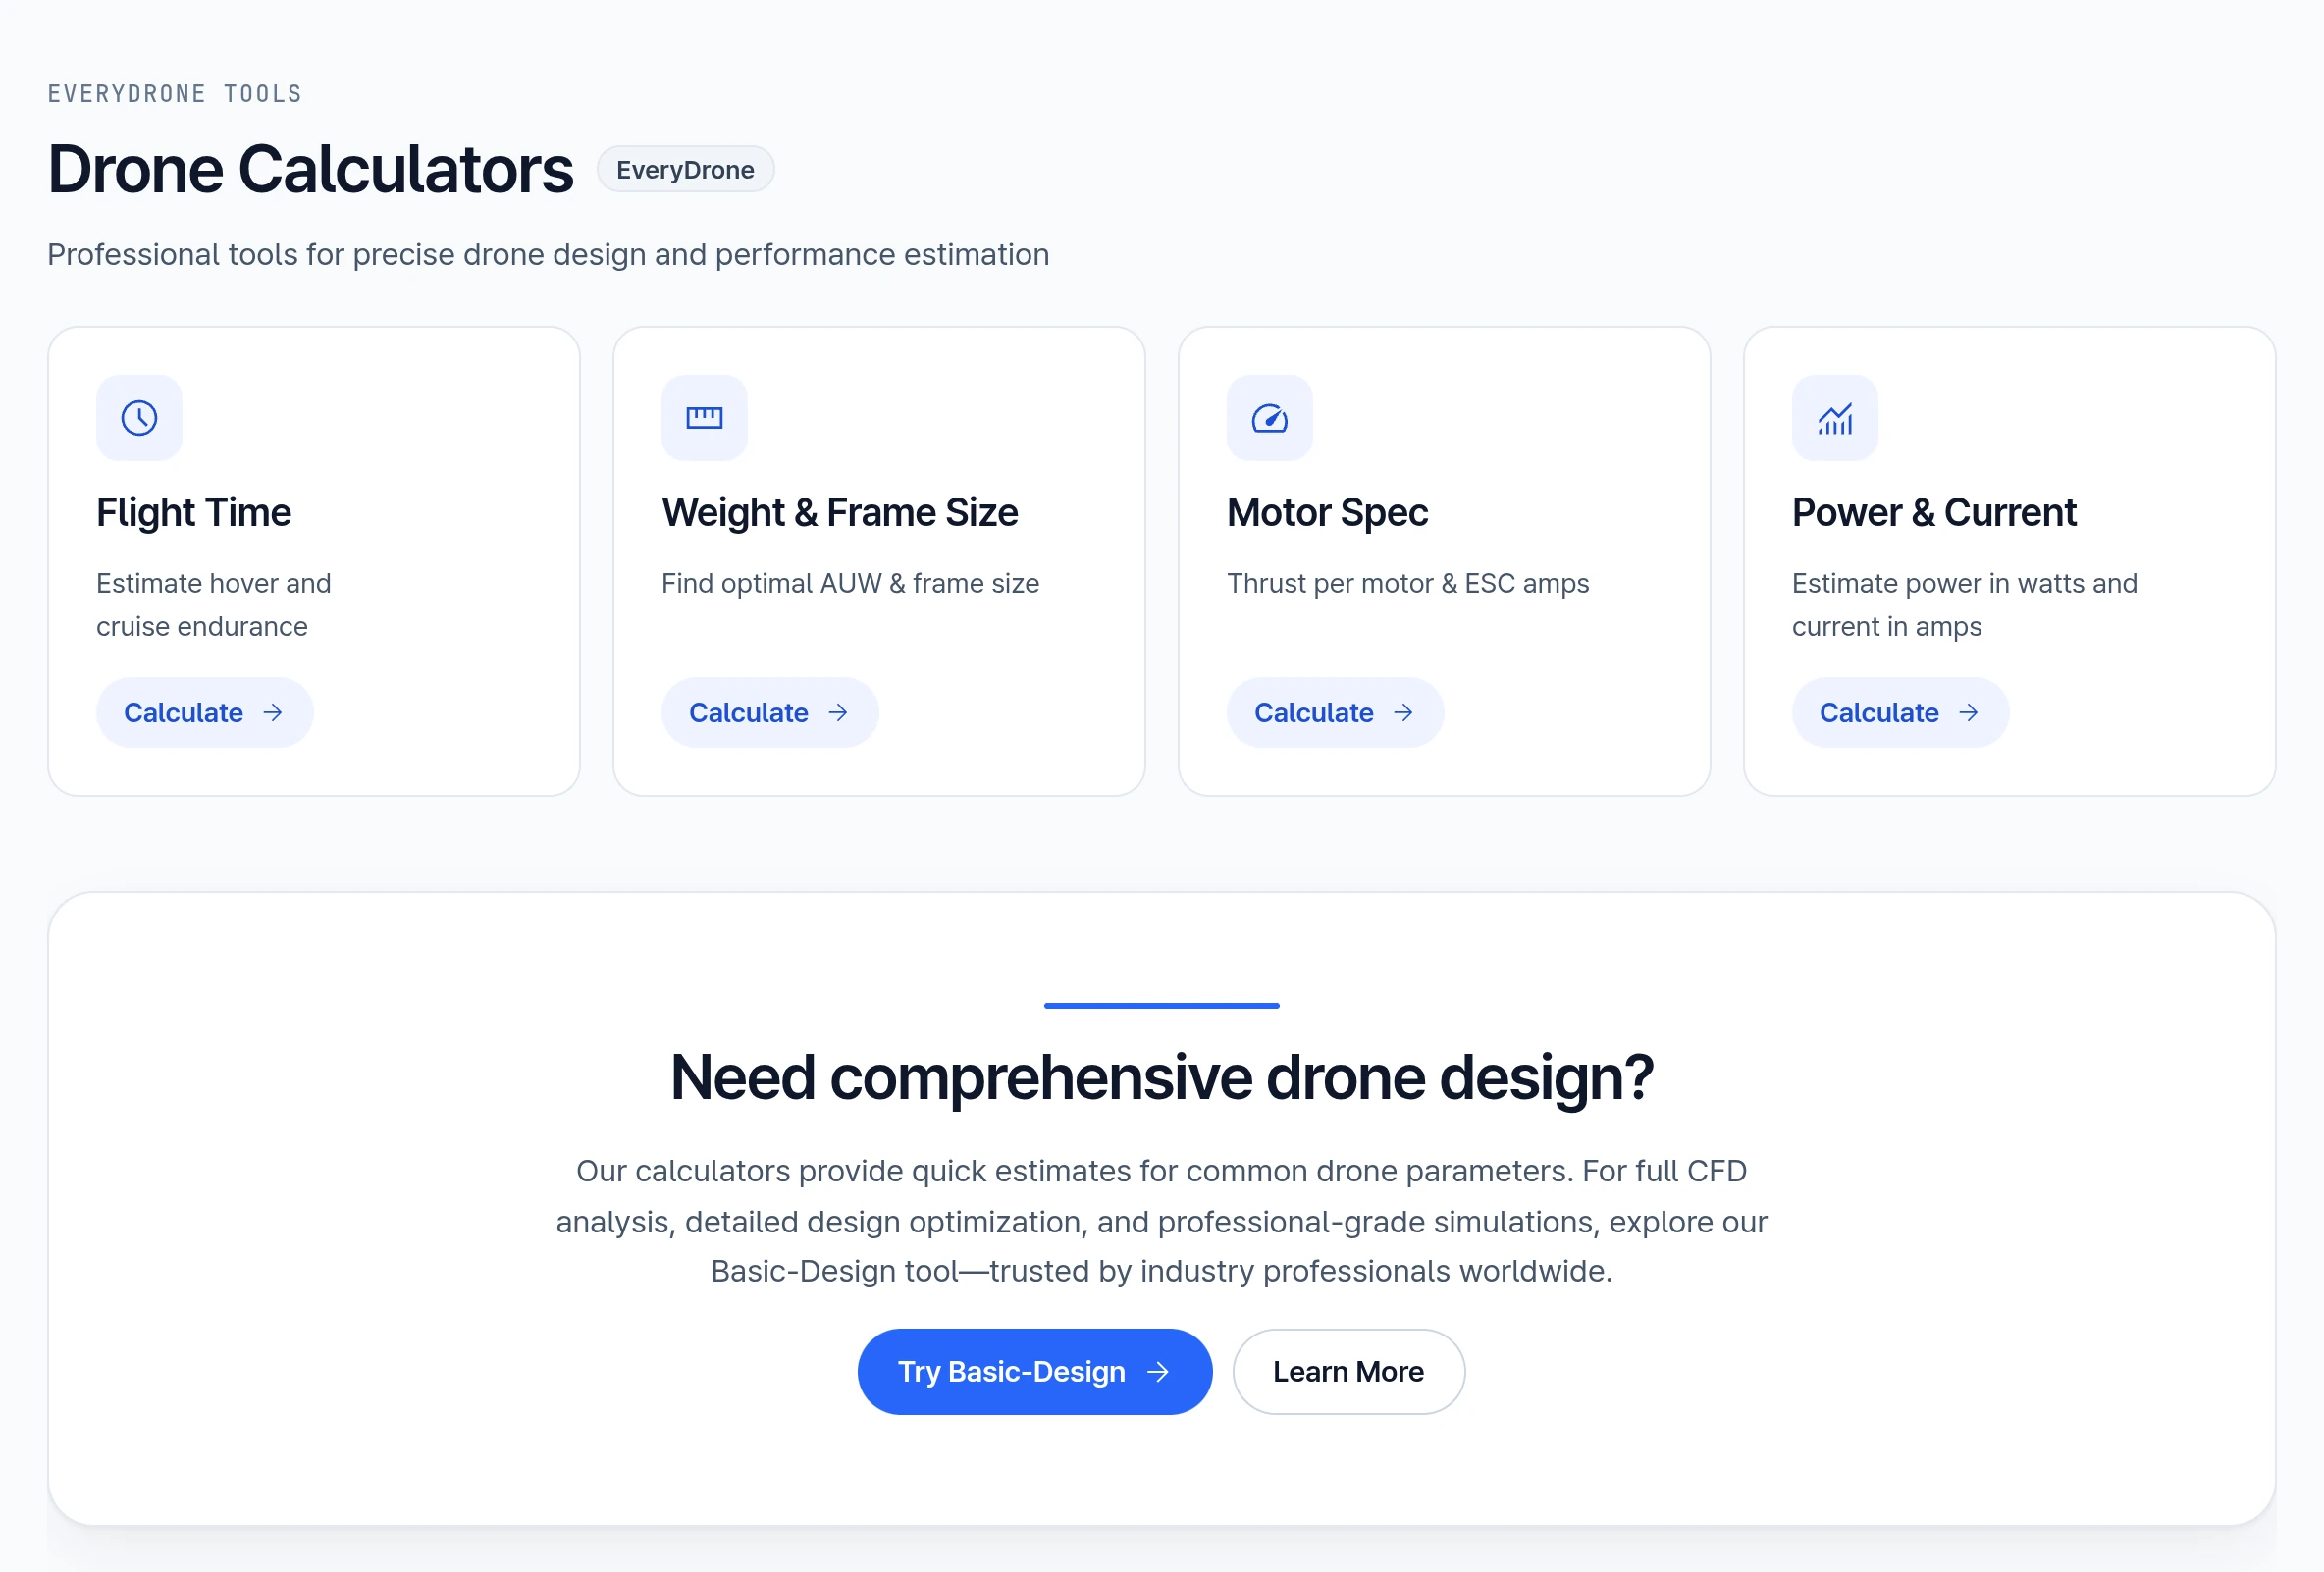
Drone Calculator is a set of tools designed to estimate drone performance based on user input parameters. Open Drone Calculators at /drone-calculators or from Tools in the dashboard; no sign-in is needed. The overview page links to each calculator, and each calculator has a navigation list for moving between them. Inputs autosave in your browser.
The overview page also offers a shortcut into Basic Drone Design through Try Basic-Design when a broader design workflow is needed. Basic Drone Design is a first-order estimate as well; CFD analysis runs in Advanced Simulation.
The calculators offer the following key functions:
- Flight Time: Estimates hover and cruise endurance based on drone weight, battery capacity, voltage, and other relevant factors.
- Weight & Frame Size: Finds the minimum frame diagonal that avoids prop strike and checks disk loading based on drone weight, rotor count, propeller diameter, and clearance.
- Motor Spec: Calculates thrust per motor and ESC current based on drone weight, thrust-to-weight ratio, battery voltage, and motor count.
- Power & Current: Estimates electrical power in watts, average and peak current, C-rate, required capacity and flight time from weight, battery and flight mode.
Calculator Descriptions
2.1. Flight Time
Hover time is the maximum time a drone can maintain stationary flight, calculated based on battery capacity and power consumption.
Calculates hover time, cruise time, and maximum range, with a battery discharge graph to visualize an idealized discharge curve.
→ View Flight Time Calculator Details
2.2. Weight & Frame Size
Finds the minimum frame size that avoids prop strike and checks disk loading, based on propeller diameter, rotor count, clearance, and drone weight.
→ View Weight & Frame Size Calculator Details
2.3. Motor Spec
Calculates the thrust each motor must produce and the ESC current to plan for. It does not evaluate a specific motor model.
→ View Motor Spec Calculator Details
2.4. Power & Current
Estimates electrical power and average and peak current based on flight mode, and checks the C-rate against battery limits and the ESC rating to plan for.
→ View Power & Current Calculator Details
Input Limits
An out-of-range value shows an error under the field, and the results keep showing the last valid result until you correct it.
| Calculator | Input |
|---|---|
| All | Drone weight (typed): 0.1-50 kg |
| Flight Time | Capacity: 100-30000 mAh; Cell Count: 1-24; propeller: 3-30 in; Cruise Speed: 0-100 km/h |
| Weight & Frame Size | Propeller: 2-30 in (Standard), 2-36 in (Advanced); Clearance: 5-50 mm |
| Motor Spec | Battery Cells: 2-12; Motors: 1-12; propeller: 3-36 in; Air Density: 0.8-1.3 kg/m³ |
| Power & Current | Capacity: 500-30000 mAh; propeller: 2-40 in; Air Density: 0.8-1.3 kg/m³ |
Quick Start
Each calculator page in this guide includes a Quick Theory section to help you understand the calculation principles. In the app, see Assumptions, When This Estimate Breaks Down and Show Underlying Model on each calculator. Results are first-order estimates; use simulation tools for detailed analysis.
Need Assistance or Have Questions?
Frequently Asked Questions: FAQ Link
Support Inquiries: support@everysim.io